
Lehre
Wintersemester

Powered Descent for Autonomous Landing Systems
Lecture (Master)
This course focuses on guidance, navigation, and control (GNC) of rockets and spacecraft during the final descent and landing phase. Students will learn about algorithms for trajectory optimization, state estimation, and closed-loop control, with applications to lunar and planetary landers, , as well as autonomous vertical landing and recovery of reusable rocket boosters such as the Falcon 9 first stage. Rather than focusing on a single methodology, the course presents and compares multiple solution strategies, highlighting their underlying principles, advantages, limitations, and suitability for different mission scenarios.
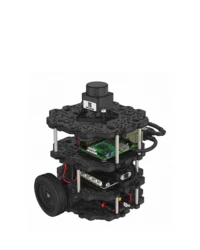
TurtleBot: Reinforcement Learning on a Real System
Practical Course (Bachelor and Master)
This practical course teaches students the steps required to apply reinforcement learning to a real-world system, including identification of a dynamic model, implementation of a simulation environment, localization, and application of the reinforcement learning agent to the TurtleBot. The first half of the course consists of guided laboratory experiments that provide the necessary theoretical and practical foundations. In the second half, students carry out a project in which they develop and train their own reinforcement learning agent, culminating in autonomous navigation of a TurtleBot through a small race track.